
Description
The Pixhawk 2.4.8 32-Bit Flight Controller is a versatile autopilot platform designed for multirotors, fixed-wing aircraft, helicopters, boats and other autonomous vehicles. Based on the FMUv2 architecture, it provides the processing power and interfaces required for advanced flight-control and autonomous navigation applications.
The controller features a STM32F427 Cortex-M4 processor with hardware floating-point processing and a dedicated backup processor for improved reliability. Its integrated sensor suite includes gyroscope, accelerometer, magnetometer and precision barometer for accurate attitude and altitude measurement.
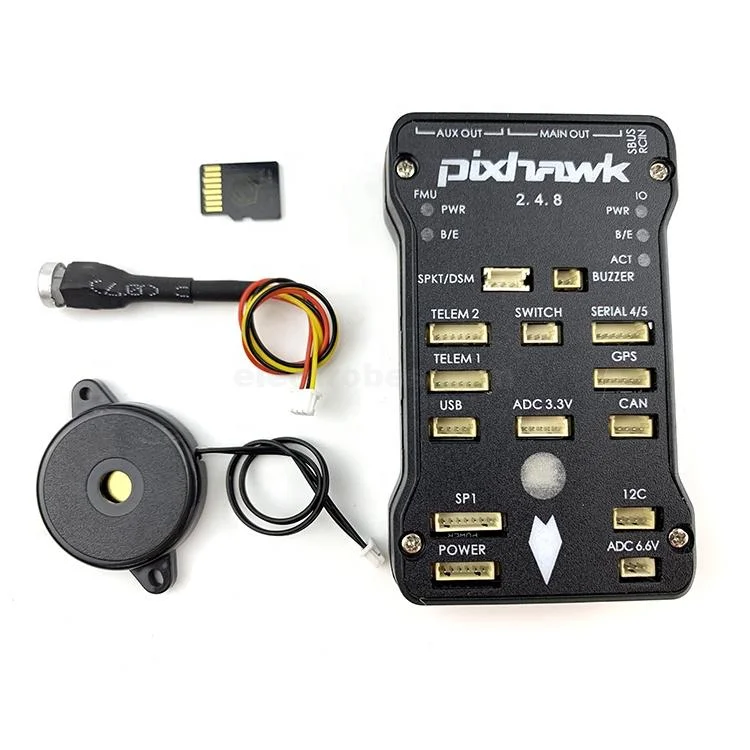
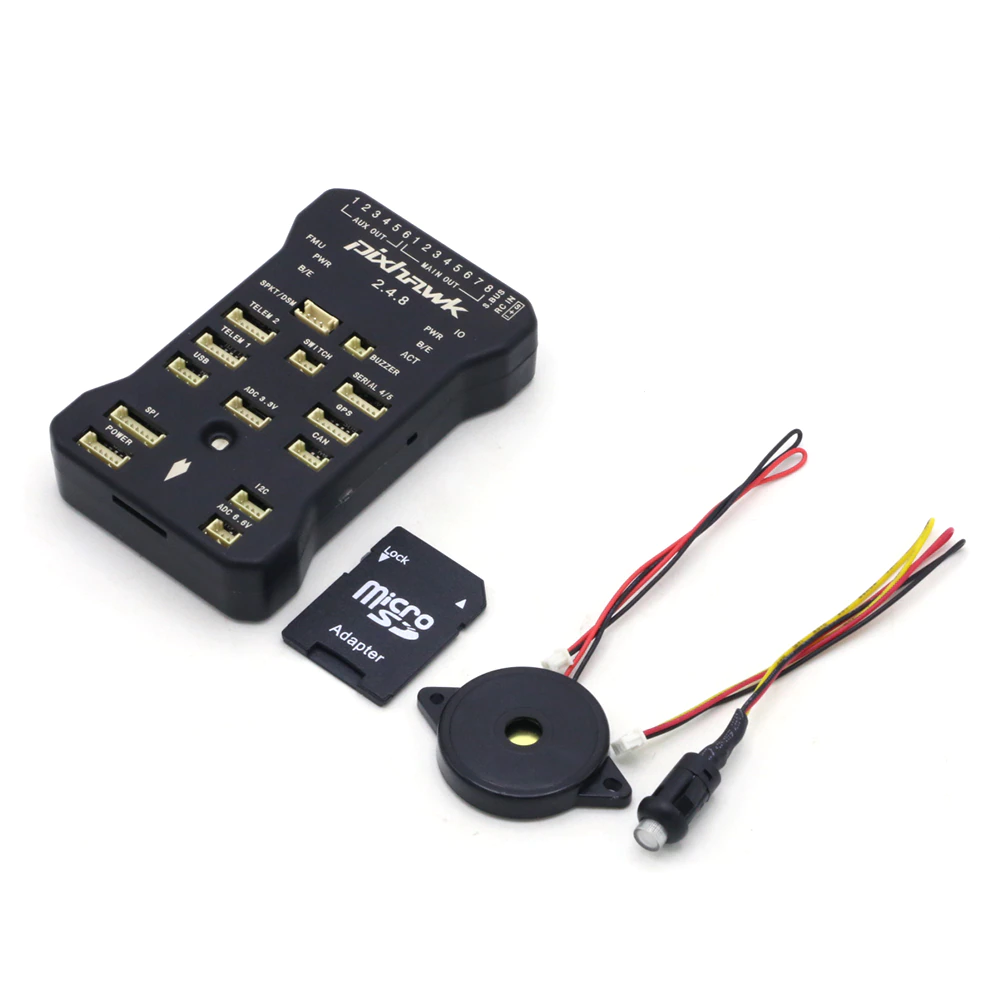
Pixhawk 2.4.8 supports a wide range of interfaces including UART, CAN, I2C, SPI, PPM, SBUS, DSM/DSM-X and RSSI, allowing it to work with various receivers, GPS modules, telemetry systems and other peripherals. It also provides 14 PWM outputs, a microSD card interface, buzzer, safety button and external USB connectivity.
With support for manual and automatic operation, the flight controller can be used for autonomous missions, waypoint navigation, FPV aircraft, custom UAVs and experimental robotics platforms.
Features
- 32-bit ARM Cortex-M4 flight controller
- STM32F427 main processor with hardware floating-point unit
- STM32F103 backup processor
- Supports PX4 and compatible autopilot firmware
- 14 PWM servo outputs
- Redundant power input
- Multiple communication interfaces
- Integrated gyroscope, accelerometer, magnetometer and barometer
- MicroSD card support for logging and configuration
- Multi-color LED indicator
- Multi-tone buzzer interface
- Safety button
- Manual and automatic flight modes
- Supports GPS waypoint and autonomous missions
- DSM/DSM-X/Spektrum satellite receiver support
- Futaba SBUS input/output support
- PPM signal input
- RSSI input
- I2C and SPI interfaces
- External micro USB interface
Specification
Microprocessor
- Main Processor: STM32F427 Cortex-M4
- CPU Frequency: 168MHz
- Flash Memory: 2MB
- RAM: 256KB
- Backup Processor: STM32F103
- Architecture: 32-bit ARM Cortex-M4
- Floating-Point Unit: Hardware FPU
Sensors
- Gyroscope: L3GD20 3-axis digital gyroscope
- Accelerometer: LSM303D 3-axis accelerometer
- Magnetometer: LSM303D 3-axis magnetometer
- IMU: MPU6000 6-axis accelerometer/gyroscope
- Barometer: MS5607 precision barometric sensor
Interfaces
- PWM Outputs: 14
- UART: 5, including high-voltage compatible UART and hardware flow-control support
- CAN: 2
- Receiver Input: PPM
- Satellite Receiver: DSM / DSM2 / DSM-X / Spektrum compatible
- SBUS: Futaba compatible input/output
- RSSI: PWM or voltage input
- I2C: Supported
- SPI: Supported
- ADC: 3.3V and 6.6V inputs
- USB: External Micro USB
- Storage: MicroSD card interface
Supported Platforms
- Quadcopter and multirotor drones
- FPV aircraft
- Fixed-wing aircraft
- Helicopters
- Autonomous boats
- RC ground vehicles
- Custom UAV and robotics projects
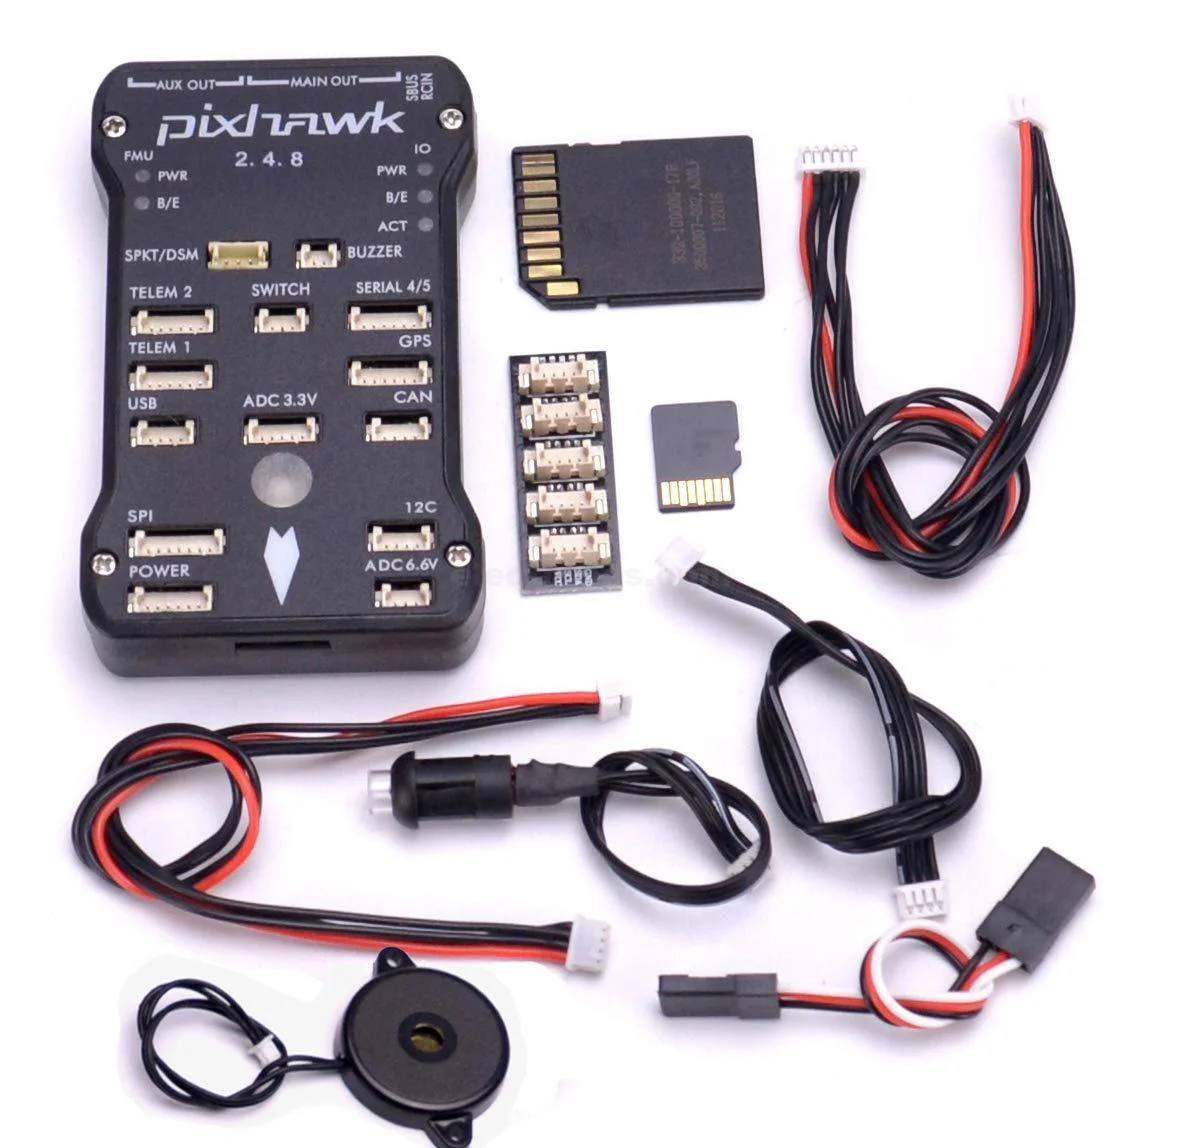
Package Includes
- 1 × Pixhawk 2.4.8 32-Bit ARM Flight Controller
- 1 × Original Protective Shell
- 1 × Safety Button
- 1 × Buzzer
- 1 × 16GB MicroSD Card with Reader
- 1 × Pixhawk I2C Splitter Expansion Module
- 1 × Servo Cable
- 1 × 4-Pin to 4-Pin Cable
- 1 × 3-Pin Dupont Cable


Reviews
There are no reviews yet.